Preview
About the Project
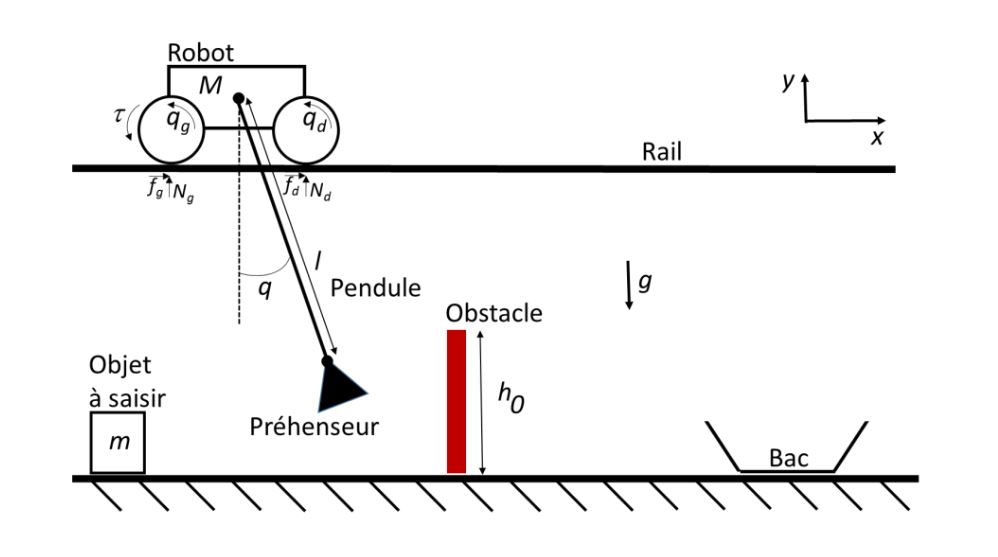
This project involves designing a robotic system that operates on a rail to transport a predetermined mass from a specific pickup point to a designated drop-off location. The robot will carry the load on a rigid rod, akin to a pendulum, which is not motorized, adding complexity to the control of the system.
To navigate over a tall obstacle, the robot precisely coordinates its sensors and actuators. This synchronization allows the robot to swing the pendulum, which is connected to the mass via an electromagnet, in a calculated manner. By carefully timing the acceleration and the pendulum's swing, the robot successfully propels the mass over the obstacle.
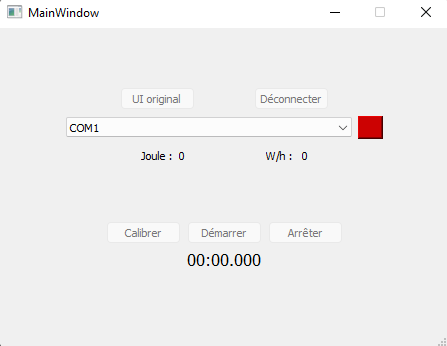
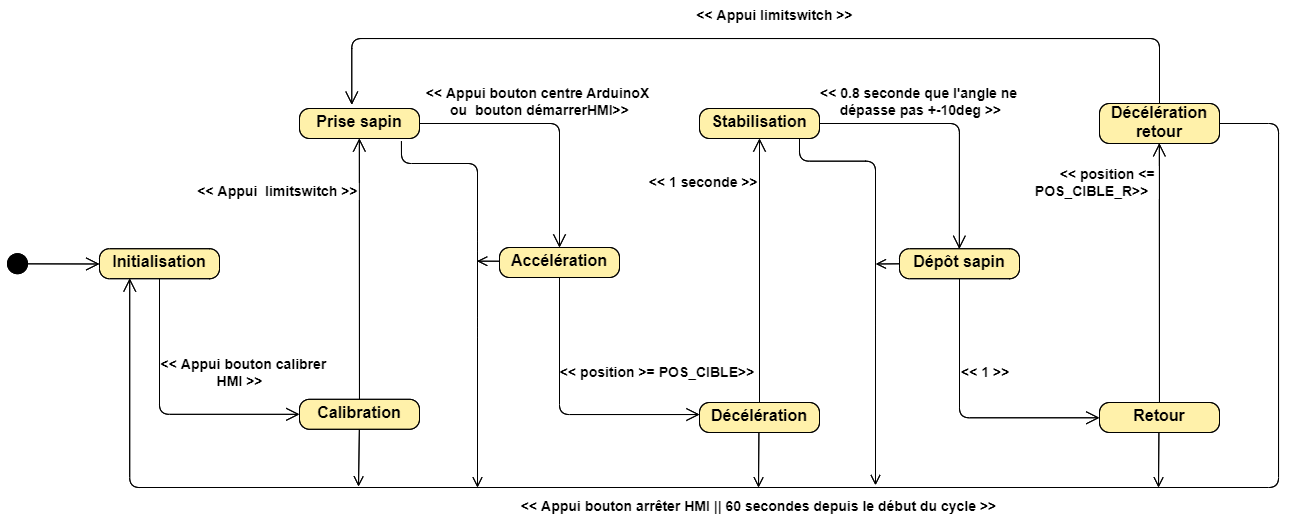
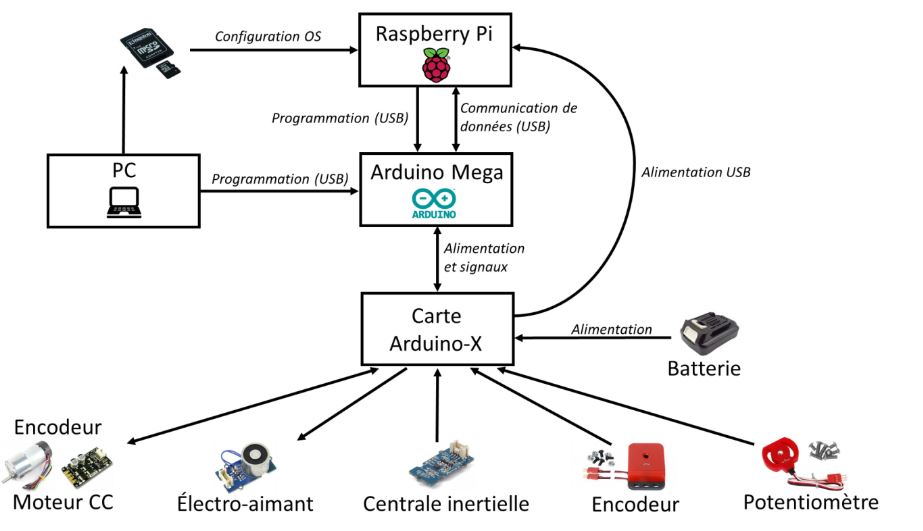
The robotic system combines a Raspberry Pi and an Arduino Mega to orchestrate the movement of a rail-mounted robot. The Arduino Mega directly controls the hardware, from the motor and encoders for movement, an electromagnet for the pendulum, and a potentiometer for angle measurement. The Raspberry Pi acts as the command center, processing data from the Arduino and providing a user interface. The user sets up and programs the system via a PC, which communicates with the Raspberry Pi. A battery powers the entire setup.
Functions
Architecture
Dynamic Modeling
Robot

QT Creator UI